THE DATA LAYER FOR PHYSICAL AI

Robot training data
from real workplaces.

The world is your training ground.
We collect egocentric, UMI and teleoperation
data around the tasks your robots need to learn.

HUMAN EXPERIENCE → MACHINE INTELLIGENCE THE WORLD, TRANSLATED.
↓ SCROLL TO EXPLORE

Egocentric. UMI. Teleoperation.
One partner for your data pipeline.

COLLECTED IN THE REAL WORLD.
BUILT AROUND YOUR MODEL.

SAMPLE DATA

See what we capture.

Stair installationConstruction siteEgocentric · 1080p · 30 fps · 2 hands trackedAbout egocentric data
Ironing linenHouseholdEgocentric · 1080p · 30 fps · 2 hands trackedAbout egocentric data

01 / THE MISSING LAYER

Robot learning starts
with human experience.

Your next breakthrough needs more of the world: the way people move, manipulate objects, and get things done.

Telepath connects your models to that experience. We collect robot training data around your tasks, with the right people, capture methods, and environments.

How robotics data collection works Why the data matters more than the model

02 / OUR DATA

Three ways to capture
robot training data.

01 / EGO / DATA ACQUISITION

The world, through
human eyes.

First-person video of people getting things done. Capture the context, object interactions, and sequences behind everyday work.

For learning from human behavior, task understanding, and visual representations of the world.

  • ↗First-person perspective
  • ↗Human–object interaction
  • ↗Natural task sequences

02 / UMI / DATA ACQUISITION

Human demonstrations.
Physical action.

Manipulation demonstrations captured with handheld grippers. Bring visual observations and gripper motion together around the task.

For teams building manipulation policies from demonstrations, with capture requirements aligned to the target setup.

  • ↗Handheld gripper capture
  • ↗Visual observations
  • ↗Gripper motion

03 / TELEOP / DATA ACQUISITION

Your embodiment.
Expert guidance.

Human-guided robot operation turns task execution into data. Collect observations and actions through the robot your team needs to study.

For embodiment-specific demonstrations, task refinement, and learning from human intervention.

  • ↗Robot observations
  • ↗Operator-guided actions
  • ↗Embodiment-specific tasks
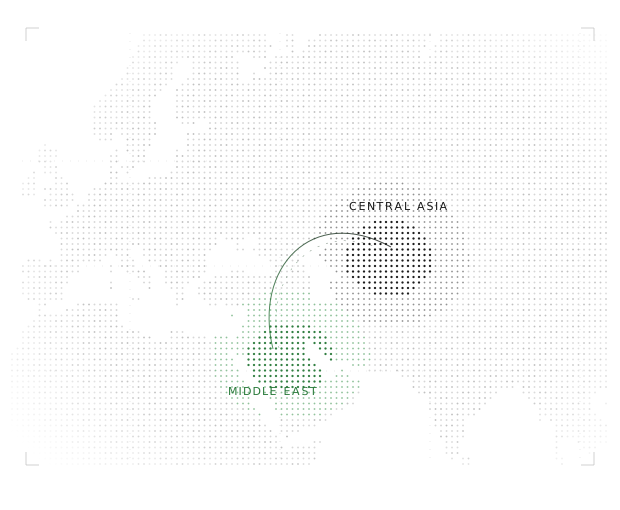
Dotted map of Eurasia and North Africa with the Middle East and Central Asia highlighted. Illustrative regional coverage; individual sites are not shown.
SITE ACCESS / TWO REGIONS

03 / OUR REACH

Collected across the
Middle East and Central Asia.

Telepath is based in Dubai and collects in real workplaces across the United Arab Emirates and the CIS, with sites in Kazakhstan, Uzbekistan, Tajikistan. The data is built for robotics and physical-AI teams in the United States, led by the San Francisco Bay Area.

Emirates
Abu Dhabi, Dubai, Sharjah, Ajman, Umm Al Quwain, Ras Al Khaimah, Fujairah.
Site types
laundries, perfume and cosmetics plants, cable factories, furniture factories, plus logistics, hospitality and retail sites.
Languages
English, Arabic, Russian for briefs and on-site instructions.
Middle East Central Asia

04 / THE TASK LANDSCAPE

Small actions.
Infinite possibilities.

From a single grasp to a complete workflow. Explore example manipulation tasks we can scope for your next collection.

Every project starts with your task definition. Capture setup, volume, and site availability are agreed together.

Pick, place, repeat.

Select different objects from bins and place them into order totes. Vary object geometry, bin layouts, and grasp approaches.

Object selection · Grasping · Placement

Start a brief with this task

EXAMPLE COLLECTION BRIEFS · CUSTOM TASKS WELCOME

05 / HOW WE WORK

How our robotics data
collection works.

You define what your model needs to learn. We work backwards from that goal to build the collection, in four stages.

The full process
  1. DefineStart with the capability.

    Align on tasks, capture methods, environments, and acceptance criteria. Define what a useful demonstration looks like before collection begins.

    YOUR OUTPUT / A SHARED COLLECTION BRIEF

  2. CollectBring the brief into the world.

    Coordinate site access, people, and capture setups around the agreed task. Collect the variations and sequences your model needs.

    YOUR OUTPUT / TASK-ALIGNED DEMONSTRATIONS

  3. ReviewMake every delivery intentional.

    Review captures against the agreed criteria. Identify gaps in the task coverage, flag collection issues, and align on what needs another pass.

    YOUR OUTPUT / REVIEWED COLLECTION DATA

  4. DeliverFit your training workflow.

    Receive the collection in the dataset structure and format agreed with your team, with the task context and metadata defined in the brief.

    YOUR OUTPUT / DATA STRUCTURED FOR YOUR TEAM

06 / WHO IS BEHIND THIS

A small team.
A ground presence.

Telepath Robotics is based in Dubai, United Arab Emirates, with site access across the Middle East and the CIS, and customers among robotics teams in the United States. Pilot programmes are open for teams that need task-specific robot training data.

About the company

WHAT A DELIVERY LOOKS LIKE

Structured for your training workflow.

Every collection is delivered in the layout and format agreed in the brief. The example below shows one common structure: episodes grouped by task, each with synchronised observations, actions where applicable, and the metadata defined at the Define stage.

collection-2026-09-table-setting/
├── brief.md                  # agreed tasks, criteria, sites
├── manifest.json             # episode index, durations, review status
├── episodes/
│   ├── ep_0001/
│   │   ├── video_ego.mp4     # first-person capture
│   │   ├── gripper.csv       # UMI pose + width (when in scope)
│   │   ├── actions.parquet   # teleop commands (when in scope)
│   │   └── meta.json         # site, operator id, variation tags
│   └── ep_0002/ …
└── review/
    └── coverage-report.md    # gaps found, re-collection notes

EXAMPLE LAYOUT · FORMATS FOLLOW YOUR BRIEF

07 / INSIGHTS

Why the data
decides the robot.

Essays on training data, distribution shift, perception, and the path from human demonstration to robot capability.

All insights

FROM THE WORLD. INTO YOUR MODEL.

Give your robots
a world to learn from.

Let’s build the data behind their next capability.

Build your dataset